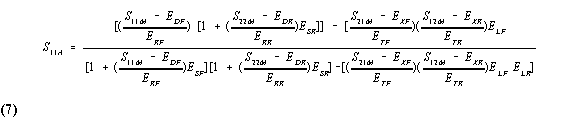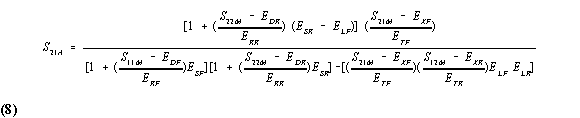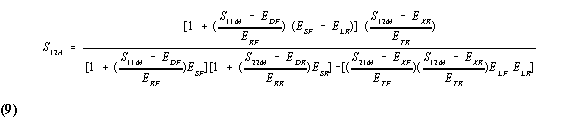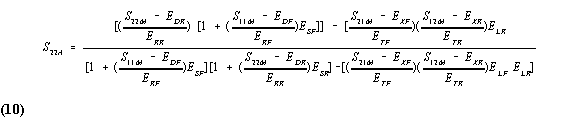Network analyser calibration
Error models and vector accuracy enhancement on the HP8510B.
Network analysers effectively compare the power of signals transmitted through, or reflected back from, a network port with the power of the incident signal at that port's input. A combination of directional couplers, isolators, transmission lines and computer calculation is used to achieve this.
A perfect measurement system would have infinite dynamic range, isolation and directivity, no impedance mismatches anywhere in the test setup, and a flat frequency response. Although modern microwave components for an analyser system can be made with excellent characteristics, there will inevitably be mismatches and errors in the system. We model the network analyser's response with a 12-term error model, in which every possible error coefficient, its direction and its position in the system are allocated.
By following a standard calibration procedure, the individual error terms can be calculated, reducing the uncertainty of a given measurement system. In practice this "perfect" network analyser is achieved by measuring the magnitude and phase response of known standard devices, using that data with the model of the measurement system to determine the error contributions, then measuring a test device and using vector mathematics to compute its actual response by removing the error terms.
The calibration must be repeated every time any part of the test setup is changed. Changing connector types, frequency ranges, system impedances or lengths of transmission line all alter the impedance or phase response of the system, and so must be characterised out to remove the resulting uncertainty.
The dynamic range and accuracy of the measurement are then limited by system noise and by how accurately the characteristics of the calibration standards are known. This is the basic concept of vector accuracy enhancement.
Sources of measurement error
Network analysis measurement errors fall into two categories.
Random errors. Non-repeatable variations due to noise, environmental changes and other physical changes in the test setup between calibration and measurement. These are any errors the system itself cannot measure, or cannot model with an acceptable degree of certainty.
Systematic errors. Repeatable errors, including mismatch and leakage terms in the test setup, isolation between the reference and test signal paths, and system frequency response.
Any measurement result is therefore the vector sum of the actual test device response plus all the error terms. The precise effect of each error term depends on its magnitude and phase relative to the actual device response. Random errors can't be precisely quantified, so they must be treated as a cumulative ambiguity in the measured data.
Fortunately, for most microwave measurements the systematic errors produce the most significant uncertainty. Since each has a predictable effect on the measured data, it can be removed to give a corrected value for the device response. For vector accuracy enhancement these uncertainties are quantified as directivity, source match, load match, isolation and tracking (frequency response). After correction, the resulting values are termed effective directivity, effective source and load match, effective isolation and effective tracking.
Directivity
The vector sum of all leakage signals appearing at the analyser input because the signal separation device can't completely separate incident and reflected waves, plus residual reflections from test cables and adapters between the signal separation device and the measurement plane. The uncertainty from directivity is independent of the test device and usually produces the major ambiguity in reflection measurements.
Standard test sets typically give uncorrected directivity of better than 26 dB. The vector accuracy enhancement described here typically produces much greater effective directivity.
Source match
The vector sum of signals appearing at the analyser test input because the source can't maintain absolutely constant power at the test device input, plus cable and adapter mismatches and losses outside the source levelling loop. The uncertainty depends on the relationship between the test device's actual input impedance and the equivalent match of the source, and it affects both transmission and reflection measurements.
Source match error is a particular problem when measuring very high or very low impedances, where there is a large mismatch at the measurement plane. Effective source match can be improved considerably with vector error correction.
Load match
The vector sum of signals appearing at the analyser test input due to impedance mismatches between the test device's output port and the analyser's test input. The uncertainty depends on the relationship between the device's actual output impedance and the effective match of the return port, and it affects all transmission measurements and reflection measurements of two-port devices.
Load match is analysed in the same way as source match and causes major transmission errors for a device whose output port is highly reflective. Vector accuracy enhancement typically improves effective load match by 15 to 20 dB.
Isolation
The vector sum of signals appearing at the analyser's detectors because of crosstalk between the reference and test signal paths, including leakage within both the RF and IF sections of the receiver. Isolation matters most in high-loss transmission measurements.
The system typically maintains better than 80 dB of isolation between the reference and test paths. Characterising and removing repeatable crosstalk and leakage, together with extensive averaging, improves effective isolation and extends the dynamic range by up to 20 dB.
Tracking
The vector sum of all variations in magnitude and phase frequency response across the test setup, including the signal separation device, test cables and adapters, and differences between the reference and test signal paths. It affects both transmission and reflection measurements.
Vector accuracy enhancement reduces these variations so that effective tracking is typically better than 0.02 dB and 0.1°.
Correcting measurement errors
The HP8510B network analyser offers a choice of frequency-response-only, one-port and two-port error models. The frequency-response-only model corrects the signal-path frequency response for the selected parameter. It may be adequate for well-matched, low-loss devices, where vector normalisation of magnitude and phase response gives enough accuracy.
The one-port model provides directivity, source match and reflection-path frequency response correction for reflection measurements. It's best for high-accuracy reflection measurements of one-port devices.
The two-port model provides full directivity, isolation, source match, load match and frequency response correction for transmission and reflection measurements of two-port devices. It gives the best magnitude and phase accuracy for two-port devices but requires all four S-parameters of the device to be measured.
The rest of this section describes these error models in more detail and, more importantly, how they can be characterised and used to reduce measurement uncertainty. In actual operation the correction isn't always done exactly as described, but the results are mathematically equivalent.
The one-port model
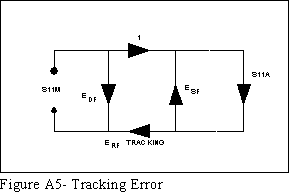
Consider measuring the reflection coefficient (magnitude and phase) of an unknown one-port device. However careful we are, the measured data will differ from the actual. Directivity, source match and tracking are the main sources of error.
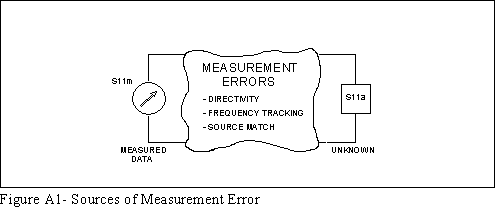
Reflection coefficient is measured by first separating the incident voltage wave (I) from the reflected wave (R), then taking the ratio of the two. Ideally (R) consists only of the wave actually reflected by the test device, S11A.
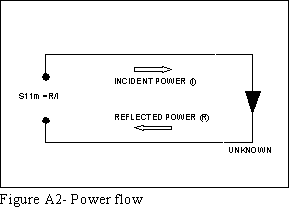
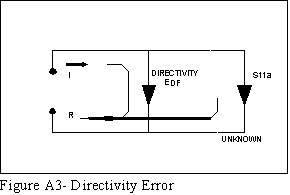
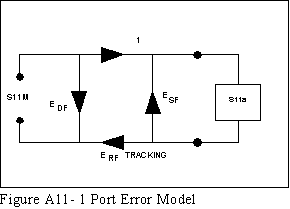
Unfortunately, not all of the incident wave reaches the unknown. Some of (I) may appear at the measurement system input through leakage in the signal separation device (coupler or bridge), and some may be reflected by imperfect adapters between the separation device and the measurement plane. The vector sum of the leakage and these miscellaneous reflections is the directivity, EDF. Our measurement is distorted when the directivity signal combines vectorially with the actual reflected signal from the unknown, S11A.
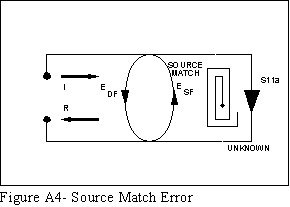
Since the test port is never exactly the characteristic impedance (normally 50 Ω), some of the reflected signal bounces off the test port, or other impedance changes further down the line, and back to the unknown, adding to the incident signal (I). This makes the magnitude and phase of the incident signal vary as a function of S11A. Levelling the source to give constant (I) reduces this error, but since the source can't be levelled exactly at the device input, levelling can't remove all power variation. This re-reflection, and the resulting variation in incident power, is the source match error, ESF.
Tracking (frequency response) error comes from differences in magnitude and phase flatness versus frequency between the test and reference signal paths, mainly due to imperfectly matched samplers and differences between the two paths. The vector sum of these variations is the reflection-path tracking error, ERF.
It can be shown that these three errors relate the actual data, S11A, to the measured data, S11M, by the following equation.
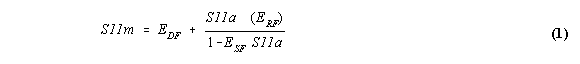
If we knew the three error terms and the measured device response at each frequency, we could simply solve for S11A to get the actual response. Because each error changes with frequency, its value must be known at every test frequency. They're found by measuring (calibrating) the system at the measurement plane with three independent standards whose S11A is known at all frequencies.
One standard is a "perfect" load, which makes S11A = 0 and essentially measures directivity. By perfect load we mean a reflectionless termination at the measurement plane: all incident energy is absorbed. With S11A = 0 the equation can be solved for EDF, the directivity error term. In practice, of course, a perfect load can never be achieved.
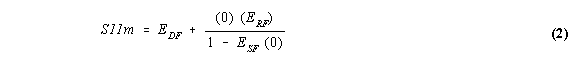
Since the measured directivity is the vector sum of the actual directivity and the actual reflection coefficient of the "perfect" load, any reflection from the termination is an error. System effective directivity becomes the actual reflection coefficient of that load. In general, any termination with return loss greater than the uncorrected system directivity reduces reflection measurement uncertainty.
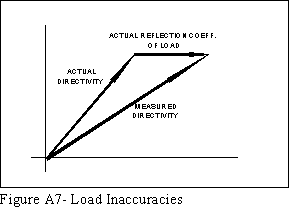
Because it's hard to make a high-quality fixed coaxial termination at microwave frequencies, a sliding load can be used at each test frequency to separate the reflection of a somewhat imperfect termination from the actual directivity.
At any single frequency, moving the sliding termination relative to the measurement plane traces a complete circle when the sliding element is displaced by half a wavelength. Its reflection coefficient magnitude stays constant while its phase changes. The radius of the circle is the actual reflection coefficient of the sliding termination, and the centre is set by the actual directivity of the test setup and the geometry of the air line within the sliding load.
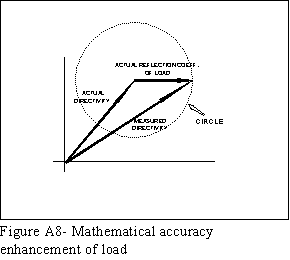
So the critical specifications for a sliding load are the mechanical dimensions (impedance) of the connector and of the transmission line between the measurement plane and the termination, and that the termination keeps a constant reflection coefficient magnitude at all positions.
The calibration sequence used here measures the sliding load at six or more positions, and the HP8510B firmware calculates the centre of the circle, which may be a 20 dB improvement over a fixed load. At low microwave frequencies, though, the sliding load causes a problem: the line has to be very long, otherwise the points bunch together and the centre is hard to determine accurately. There it's often better to use a fixed load. The convention is a fixed load below 2 GHz and a sliding load above 2 GHz.
Next a short circuit is used to establish another known condition.
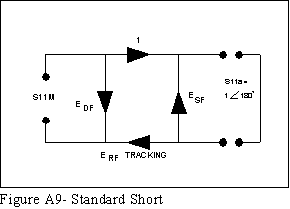
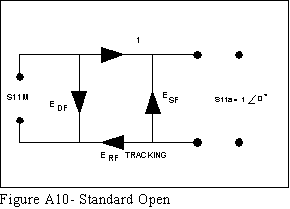
The open circuit gives the third independent condition. Values for EDF (directivity), ESF (source match) and ERF (reflection tracking) are then computed and stored.
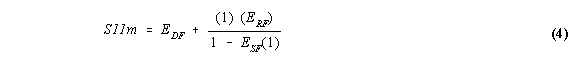
Now we measure the unknown to obtain its measured response, S11M, at each frequency.
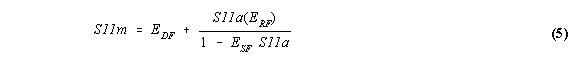
This is the one-port error model equation solved for S11A. Since we have the three errors and S11M at each test frequency, we can now compute S11A.
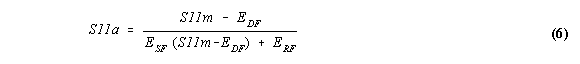
For reflection measurements on two-port devices the same technique applies, but the device's output port must be terminated in the system characteristic impedance. This termination should be at least as good (as low a reflection coefficient) as the load used to determine directivity. The extra reflection error from an imperfect termination at the output port isn't included in the one-port model.
The two-port model
Now consider measuring the transmission coefficient (magnitude and phase) of an unknown two-port device. The major sources of error are tracking, source match, load match and isolation, and these are reduced or removed using the two-port error model.
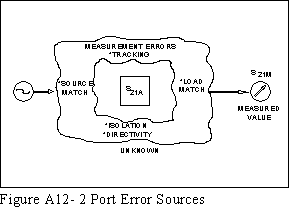
Transmission coefficient is measured by taking the ratio of the incident wave (I) and the transmitted wave (T). Ideally (I) consists only of power delivered by the source, and (T) only of power emerging at the device output.
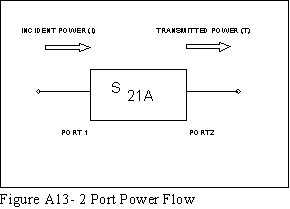
As in the reflection model, source match can make the incident signal vary as a function of the device's S11A. And since the test set's transmission return port is never exactly the characteristic impedance, some of the transmitted signal is reflected from port 2, and from other mismatches between the device output and the detector, back to the device. Part of this wave may be re-reflected at port 2, affecting S21M, or transmitted back through the device to appear at port 1, affecting S11M. This error, which makes the transmitted signal vary as a function of S22A, is called load match, ELF.
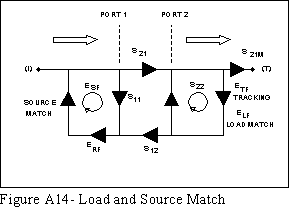
The measured S21M contains components that vary with the relationship between ESF and S11A, and between ELF and S22A, so the device's input and output reflection coefficients must be measured and stored for use in the S21A correction. The test setup is therefore calibrated for reflection as described above, establishing directivity EDF, source match ESF and reflection tracking ERF.
With a calibrated port for reflection measurements, we connect the through and determine load match, ELF, by measuring the reflection coefficient of the through connection.
Transmission tracking is then measured with the through connection; the data is corrected for source and load match effects and stored as ETF.
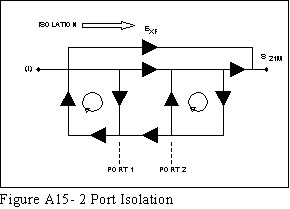
Isolation, EXF, is the part of the incident wave that reaches the receiver detectors without passing through the test device. It's measured with the test set in its transmission configuration and terminations fitted where the device will be connected.
The microwave test set installed in the Bath University microwave research laboratory (HP8515A) can measure both forward and reverse characteristics of the device without it being removed and physically reversed. For these test sets the full two-port model includes terms for:
| Error term | Forward | Reverse |
|---|---|---|
| Directivity | EDF | EDR |
| Isolation | EXF | EXR |
| Source match | ESF | ESR |
| Load match | ELF | ELR |
| Transmission tracking | ETF | ETR |
| Reflection tracking | ERF | ERR |
So there are two sets of six error terms, one forward and one reverse: twelve in all.
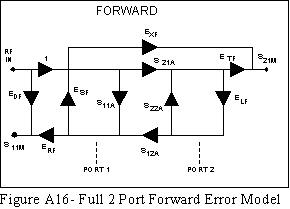
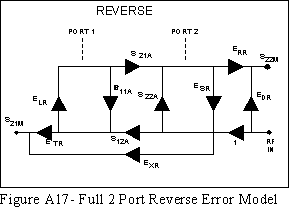
If the test set can't switch between forward and reverse, the reverse terms can't be measured directly, and the forward terms are used in their place when the device is reversed by hand. The one-path two-port error model makes this assumption.
Below are the two-port error model equations for all four S-parameters of a two-port device. The mathematics of this comprehensive model uses all the forward and reverse error terms and measured values, so to fully correct any one parameter of a two-port device, all four S-parameters must be measured.