Cybernetics in industry
A 1990 report on industrial robots: history, anatomy, applications, economics and social impact.
The photographs and brochure pages from the original printed report weren't carried over to the web.
Introduction: here comes the automatic factory
Robots have been talked about and tinkered with ever since Czech writer Karel Čapek's 1921 play, Rossum's Universal Robots, brought the word into the English language. But it was the advance of the microchip in the 1970s that made enormous advances in robotics possible. The first generation of computer-controlled robots in the 1970s were called universal transfer devices (UTDs) and were little more than mechanical arms. They were also "deaf, dumb and blind" and very inflexible, used for tasks such as spot-welding, paint-spraying, loading and stacking.
Now, improvements in computer software and the development of vision systems (robots that see) are transforming the prospects for these "steel-collar workers". Robots are used increasingly in general manufacturing, especially in sectors like the motor industry. Robots enjoyed something of a boom in the early 1980s in the USA and Europe as firms flocked into the business. In Japan, Fujitsu already has a plant where robots help make other robots. In another Japanese factory a robot recently crushed a worker to death, causing the world's first "high-tech murder".
Robots have come to symbolise the high-level industrialisation of society. Industrial robots appear to be the wave of the future in manufacturing and in the drive for greater industrial productivity. A flood of articles, magazines and conferences on production automation, and robotics in particular, shows this; so do trade shows and meetings.
Improved productivity, reduced costs and better manufacturing quality are the objectives on which most agree. How to achieve them is less clear. Politicians and labour leaders want government intervention to rebuild conventional old plants and put workers back on the job. Academics want new approaches to manufacturing processes. Economic planners call for a shift to the manufacturing industries of the future, such as aerospace, electronics and computers. To increase productivity and ease some of the social problems, changes in methods have been, and are expected to be, introduced at all levels of industrial production through the use of computers. One overall trend stands out: the development of computer-automated manufacturing, leading towards the computer-integrated automatic factory as a complete entity. This trend is held back, however, by a loss of flexibility to change products quickly while keeping production cost-effective. This is particularly true of small- and mid-volume production. Companies manufacturing in batches therefore mostly still use human-operated machines organised on conventional workshop or assembly-line principles. High-volume producers, by contrast, use highly automated transfer lines where possible, which become more cost-effective as volume increases.
The advent of numerical control and numerically controlled machining centres improved the situation somewhat for low-volume producers of parts. Nevertheless, most mid-volume manufacturers are still looking for production systems that can bring per-piece costs well below those of the job shop with traditional technology. Computerised manufacturing systems, flexible manufacturing systems, higher-level direct numerical control and so on are some of the more promising answers offered by machine-tool builders. Although each builder's approach varies, the ultimate objectives are the same:
- Minimise in-process inventory, that is, the parts bins needed to perform the task.
- Minimise lead time, the idle time when nothing is happening.
- Minimise direct labour.
- Minimise tool changes and set-ups.
- Maximise equipment utilisation.
- Maximise flexibility.
In working towards these objectives, robots quietly take their place alongside people on the production line, raising productivity and doing the dirty work. They can do most of the work still done by humans, even in plants full of automated heavy machinery. They can handle materials, load and unload, sort, stack and assemble. They can position workpieces on machines, weld, spray, rivet, rout, sand and grind. They can do many of the monotonous, hot, disagreeable and dangerous tasks formerly given to people, as well as new tasks people cannot do. They can work for thousands of hours with typically less than two per cent downtime. Robots can be reprogrammed for different tasks, and the digital electronics of their control systems puts them squarely in the computer-aided manufacturing (CAM) arena.
The purpose of this report is to examine the use of robotics in industry, with a view to evaluating its impact on the company, its workforce and society as a whole.
The history of cybernetics
In Čapek's play, the engineer hero Rossum creates a new breed of robots to do the world's dirty work. He took the name for his human-like creatures from the Czech word robota, meaning forced or slave labour. After taking on all of humanity's unpleasant jobs and fighting its wars, Rossum's robots eventually rise up and take over the world, like so many Frankenstein's monsters.
Unfortunately this has given robots a bad name and an unjustified reputation, perpetuated over the years by, for example, Isaac Asimov's science fiction of the 1940s and films like Star Wars with its robot R2-D2. Today's industrial robots are really nothing like Čapek's humanoids. Most cannot see, and none can hear, smell or think. They are simply machine tools, typically no more than a mechanical arm controlled by a computer that can be programmed to carry out different movements. The Robot Institute of America defines a robot as "a reprogrammable, multifunctional manipulator designed to move material, parts, tools or specialised devices through variable programmed motions for the performance of a variety of tasks."
The age of the industrial robot really began in 1946, when US inventor George Devol developed a memory device for controlling machines. Devol filed the first patent for a programmable arm in 1954, and in 1960 teamed up with American engineer Joe Engelberger to form Unimation, the first company to make and sell industrial robots. By using the word "robot" to generate interest in their product, they actually succeeded in confusing everyone!
The marketing ploy worked in that Unimation's robots generated piles of press cuttings, if not revenue. Industrial robot sales were very slow to take off: the world's first industrial robot was installed in 1961 at a General Motors factory in New Jersey, but high costs and teething troubles delayed later installations so much that Unimation didn't make a profit until 1975. Even so, the potential of robots to increase productivity and reduce manpower was becoming steadily more apparent.
In The Robotics Revolution (Peter B. Scott, 1984) it's pointed out that these so-called first-generation robots were ideal for dirty, repetitive jobs such as welding, paint-spraying, grinding, moulding and casting. Of the 4,700 robots in use in the USA in 1981, for instance, 1,500 were used for welding, 850 in foundries, 840 for loading and 540 for paint-spraying. Only 100 were used for assembly. Scott's second-generation machines are able to "see" and "touch", while the coming third generation will have intelligence and massive computing power, enabling them to "infer logically", that is, to work out for themselves how to do something.
Three key developments sparked the robotics boom of the early 1980s. The first, of course, was the microchip, which made robots' computer brains much cheaper and smaller. Second, fear of foreign competition, particularly from Japan, and the revelation that US productivity gains in the 1970s were minuscule and lagging behind the rest of the world, stirred US manufacturers into action. Between 1947 and 1965 US manufacturing productivity grew by an average of 3.4 per cent a year, but this fell to 2.3 per cent in 1965–75 and below 1 per cent in the late 1970s. Third, wage inflation and extra fringe benefits were dramatically increasing the cost of human assembly-line workers relative to robots. The incentive to invest in new technology had never been greater.
Furthermore, a number of systems already up and running, particularly in the vehicle industry, clearly demonstrated the productivity gains robots could bring in the right situations. Workforce representatives were generally impressed by their use in hazardous environments such as furnaces, chemical plants, nuclear power stations, outer space and the ocean floor. Besides, there was no great merit in having people work in dirty, noisy, dusty and dangerous jobs.
By the end of 1984, according to British Robot Association figures, there were about 100,000 robot devices at work in the world: 64,600 in Japan, 13,000 in the USA, 6,600 in West Germany, 3,380 in France, 2,850 in Italy and 2,600 in the UK. Per head, the European order was Sweden first, with about 19 robots per 10,000 production workers, followed by Belgium and West Germany with only 3 per 10,000, about the same as the USA and far fewer than Japan. By the end of 1985 the USA had 20,000, West Germany 8,800 and the UK 3,200.
In the mad scramble into robotics in the USA in the early 1980s, computer giant IBM entered the market with two home-developed robots, while General Electric (partly through its acquisition of Calma) and Westinghouse (which bought Unimation in 1982) aimed to offer "complete solutions" for factory automation. But some alleged that the robotics revolution had been overblown, with too many players (perhaps 250 worldwide) competing in what was still a fairly small market. As Joe Engelberger once quipped, "I sold the idea of robots to my competitors, not my customers." The Japanese were quick to bring a whole range of robots to market, from small pick-and-place units to whole systems. A shake-out seems inevitable: many smaller specialist robot companies may be forced out of business or into mergers with larger companies that have the resources to compete in the factory-of-the-future market. American Robot Corporation, for example, sold out to Ford in 1985.
The UK robotics industry has been largely influenced by the US and has not been at the forefront of design. Relatively few companies use robots as yet, and they're only beginning to appear in the car industry, especially in the Japanese-owned Nissan plant. Other applications include R. A. Lister in Dursley, Gloucestershire, where small robots remove flash from die castings.
Arguments for and against robots
The arguments for and against robots in production industry are closely related to those about industrial automation in general. Production automation became a national issue in the late 1950s and early 1960s, when labour leaders and government officials debated its pros and cons. Even business leaders, who see themselves as champions of technological progress, have at times questioned whether automation was really worth its high investment cost.
The motivating factors for introducing robotic systems into production can be divided into technical, economic and social categories.
Technical factors. Human capabilities are often not enough to meet modern requirements for precision, speed, endurance, strength, uniformity and so on. Robotic systems offer these capabilities. They also bridge the rigidity of fixed and direct numerical control automation and the flexibility of people. They offer:
- high flexibility of product type and variation, with smaller losses in preparation time than conventional automation
- better product quality, fewer rejects and less waste than labour-intensive production.
Economic factors. An overriding consideration in applying robotic systems is the economic picture. Ever-increasing competition and rising labour costs call for increased productivity. Robotic systems can help by:
- making maximum use of capital-intensive production facilities, possibly in three shifts around the clock
- reducing production losses from interruptions, absenteeism and labour shortages
- reducing in-process inventory
- reducing manufacturing lead time.
Social factors. The impact on the human side of production can be beneficial in several ways. Robots can take on many low-level or otherwise undesirable tasks, including work in dangerous or unhealthy environments, monotonous jobs with short repeating cycles, and heavy physical work. The benefits include:
- fewer accidents
- removal of conditions dangerous to health
- shorter working hours
- higher living standards.
The growth of the robotics industry will itself also create jobs. This has been especially clear in the computer industry: as companies like IBM, Burroughs, Digital Equipment and Honeywell grew, new jobs were created, not only for their own staff but for the programmers, systems engineers and others needed to use and operate the computers. Similar arguments could be made for robotic systems.
The arguments against robotic systems are also closely related to those against automation generally. They include:
- humanity being subdued by the machine
- a reduced labour force and resulting unemployment.
These questions won't easily be resolved. The impact of robotics on industrialised nations and society must be reviewed in the light of new evidence each year.
The anatomy of robots
Robot capabilities range from very simple, repetitive point-to-point motions to extremely versatile movements controlled and sequenced by a computer as part of a complete, integrated manufacturing system.
All robots consist of two major systems. First there are the moving parts, chiefly the arm, wrist and hand. This is the most obvious part of a robot to an outside observer. Complementing it is the control system. At its simplest this might be just a series of adjustable mechanical stops or limit switches. At the other extreme are computer controls, which give the robot a programmable memory. This lets the robot follow a path defined accurately along its whole length by a series of continuous coordinates, and lets it be coupled to another computer or machine control system to synchronise it for the most efficient and safe production possible. All industrial robots fall into one of three classes.
Limited-sequence robots
As the name implies, a limited-sequence robot sits at the least sophisticated end of the scale. Typically these robots use mechanical stops and limit switches to control the movement of arm and hand. Sequences can often be set up with adjustable plugboards linked to electromechanical switching, meaning a combination of relays and rotary or stepping switches. With this kind of control, only the end positions of the robot's limbs can be specified. The arm can be taken from point A to point B, but the path in between is not controlled; the controls simply switch the drives on and off at the ends of travel. This has earned such machines the nickname "pick-and-place" robots.
The arm drive could be electric, pneumatic or hydraulic. Most robots of this type are small and tend to move faster than their bigger, more complicated relatives. Mechanical stops and limit switches give good positional accuracy, typically repeatable to better than ±0.5 mm. The purchase price is around 25–50% of that of bigger robots. They've been used successfully in die-casting, press loading, plastics moulding and as part of special-purpose automation. Their disadvantages, apart from the obvious control limitations, are that they're likely to have few articulations, and setting them up is more time-consuming and tedious than for robots with better controls. The number of movements in a production sequence is limited by the number of limit switches, stops and programmable switches the robot has. Such robots aren't "taught" their job but set up the way an automatic machine would be adjusted. There's no memory as such, other than what's embodied in the plugboard settings and the mechanical stops.
Programming a limited-sequence robot usually means setting all the end stops in the right positions and adjusting contacts in the sequencing unit so every step happens in the correct order. A pegboard is often used to speed up sequencing.
Here is how a limited-sequence device works. To start a sequence, the controller switches power to the relevant drive. For electric drives it will probably close a relay; for hydraulic or pneumatic drives, it operates the appropriate solenoid valves. The motion normally continues until the moving limb is physically stopped by an end stop, the shock cushioned by some form of absorber. So there are only two positions where the moving part can come to rest: the beginning and end of a programmed move. A limit switch cuts off the motive power as soon as the end stop is reached, and also signals the controller that the movement is complete so the next one can start.
The controller is a sequencing or stepping switch. It could be a set of contacts operated by cams on a spindle, rotated a few degrees at a time by a small electric motor. Each time the sequencer receives its drive signal it steps to its next position, switching power on or off to a particular part of the robot. This repeats step by step until the program is complete, the manufacturing cycle is finished, and the robot is ready to begin again.
So how does the controller make sure the robot doesn't put its arm into the closing jaws of a press, or try to load a workpiece into a spinning chuck? The robot can't see the machine it's operating; it has no senses equivalent to a human operator's. Some way must be found to make it aware of the real world. This is done by fitting additional limit switches or other sensors to the machine being operated, connected to the controller to give the sequencer extra signals alongside those from the robot's own switches. The robot's movements are thus carefully interlocked with the machine. This stops the robot from trying to commit suicide, avoids collision damage to nearby plant, and lets it carry out its operations not only in the right order but at the right moments.
The original report included details of a small pick-and-place robot designed and built by M. Collins of Collins Tooling, Cheltenham, to remove sprues from plastic injection mouldings. It had four articulations including the gripper, was pneumatically powered and computer controlled. White nylon blocks housed the limit microswitches, whose actuators could be moved to alter the travel of each articulation.
Playback robots with point-to-point control
One characteristic of limited-sequence robots is that they're generally hard to reprogram. That's because their control system and memory are embodied in a complex, interdependent set of limit switches, interlocks, end stops and wiring. Not only is such an electromechanical arrangement tedious to change, it also limits the number of sequence steps that can practically be accommodated. Another way to control each limb's position relies on a servo mechanism. Each moving limb is fitted with a device that produces an electrical signal proportional to its position. The drive moves in the direction that reduces the position error, and as the limb nears the target the error signal falls until it reaches zero and the limb stops in the right place. This is analogue control, and in practice it takes considerable engineering skill to get good positional accuracy without oscillation.
If a knob on a control panel varies the command signal for a limb, that limb will move as the knob turns. This gives a form of remote control, and the panel can have as many knobs as there are limbs, giving an operator the means to drive the robot.
What we've described so far is a manipulator, not a robot. A memory unit must be added before it can properly be called a robot. Once there is a memory, a very flexible robot results. The position of the limbs at each step, and the whole sequence, are recorded in memory, which then drives all the servo systems. Setting up such a robot is far easier than setting up a limited-sequence one. You simply drive the limbs to the required position for each step using the controls, then press a button to record the robot's exact state before moving to the next step. In other words, the robot can be taught by driving it through every stage of the operation.
For obvious reasons a robot taught this way is called a playback robot. Safety and control interlocks between the robot and the machinery it operates are still essential to prevent collisions and other problems. Besides being far easier to set up, the memory can take advantage of modern technology by digitising all the position data, so the robot can remember a large number of steps. Point-to-point robots can obviously do any job a limited-sequence robot can. Given enough memory, they can also do more sophisticated jobs such as palletising, stacking and spot welding.
Playback robots with continuous-path control
Some manufacturing applications require control not only of the start and end points of each step, but of the path the robot's hand follows between them. Seam welding is a good example: the robot must move a welding gun along a complex contour at the right speed to produce a strong, neat weld. One way to view continuous-path control is as a logical extension of point-to-point control: give the robot a memory large enough to make path control continuous to all intents and purposes.
Alternatively, a continuous-path robot can be taught in real time. The operator takes hold of the robot's hand and leads it through the motions it will have to perform, trying to match the speed required. During this teaching the robot records its movements and hand attitudes continuously, or nearly so. It does this with an internal timing system, which might for example be synchronised with the 50 Hz mains supply, sampling its movements 50 times a second and committing the results to memory. Even at that rate a great deal of data accumulates, so such robots often store programs on magnetic tape.
To make continuous-path robots more useful, the playback speed can usually differ from the teaching speed. This helps the operator a great deal: in some applications the actual travel speed is very slow, and it's easier to teach at a faster speed and make a smoother run, free from hand shake. The converse also applies: for higher-speed programs, such as applying a bead of sealant, it may be better to teach more slowly than the playback speed.
The original report also reproduced a FIAT brochure on its robotic assembly facilities in Italy. These are continuous-path playback robots, some combined with the ability to see through small CCD cameras mounted on their arms, which can make out the outline of objects.
Present applications of robots
Since robots were introduced to industry in the 1960s, the number of uses found for them has grown dramatically. Here are some of them.
Die casting
In die casting, parts are formed by forcing molten non-ferrous metal under pressure into metal moulds called dies. Alloys of lead, aluminium, zinc, magnesium, copper and brass are commonly used. The die-casting machine consists mainly of two heavy platens, one fixed and one moving, which hold the dies, normally made in two halves. The whole machine is massive enough to withstand very high pressures, typically thousands of pounds per square inch.
In operation, the die halves are closed and locked together automatically under pressure from air cylinders or hydraulics. Molten metal is delivered to a pump, which may be cold or heated to the metal's temperature depending on the method. The pump's plunger drives the metal quickly through the feed system while air escapes from the dies through vents. Enough metal is injected in each shot to overflow wells built into the dies and produce some surplus, or "flash". Pressure is held long enough for the metal to solidify, then the die opens and the casting is ejected.
After removal from the machine, the casting is often quenched in a water bath. In the simplest case it simply drops into the bath on ejection. From the quench tank it goes to a trim press, which removes all the excess metal.
The die-casting industry pioneered the use of robots, the first being introduced as early as 1961. Since then more than two million hours of operation have accumulated in workshops across Europe and the USA, in many cases running 7 days a week, 24 hours a day, on long and short runs.
More and more die casters use robots to keep up with modern foundry practice and competition. Unimate robots at work in die casting far outnumber all other robots combined, working in both independent and captive shops, round the clock and on single shifts, handling light and heavy loads.
Robots have been used in many ways in die casting, and without exception they've delivered high net yields, better and more consistent quality, reduced die wear and lower costs. Downtime from malfunctions averages less than 3%. On short-run jobs where the program changes often, die setters find they can teach the robot new routines after only a short period of instruction. In the more aggressive shops, up to 12 die-casting machines can be served by six robots under the supervision of one operator. These are some of the operations robots now handle successfully in die-casting shops.
- Unloading one machine, quenching the part and disposing of it. The simplest and least sophisticated use, and so probably the one with the lowest economic return.
- Unloading one machine and rough trimming. Similar to the above, but with a trimming operation added, usually to separate the rough casting into several parts. Rough trimming is needed where multi-cavity dies cast several parts at once, which must then be separated, sorted, trimmed and finished. Quenching is often unnecessary, and careful positioning in the separating tool is seldom required, so productivity stays high. There's also no trim or flash to dispose of, since the operation just separates the parts from the sprue and runner.
- Alternately unloading two die-casting machines. The long reach of robots means they can unload two machines alternately. This is generally used for larger castings with longer cycle times. Depending on those times, trimming or separating may also fit into the robot's sequence. This mode makes the most of the robot, particularly in independent shops where short runs put a premium on set-up time. Once the robot has been taught a basic program for each machine, a die change needs at most a slight adjustment of the pick-up point to suit the new sprue location.
- Unloading one machine, quenching the part and trimming it. A dynamically capable robot can unload a die-casting machine and quench the part at around 500 shots an hour. With larger castings the production rate is much lower, leaving the robot plenty of idle time to use productively. If a trim press is moved within reach, trimming can be done well within the machine's cycle time. Long runs suit this especially, since set-up time and cost become minor. It's particularly attractive when the part needs no further work after trimming, such as plating, inspection or hand finishing, as it can then be packed straight for delivery.
- Unloading with die care performed by the robot. The robot's versatility and repeatability let it blow off flash and apply lubricant more effectively than a human operator or any other automatic unloading method. This is particularly useful in aluminium die casting. Proper die care takes an appreciable share of the casting cycle and so strongly affects production rate, and higher-temperature alloys need more meticulous care. Coupled with short runs, this can make automatic die-care methods, which need their own set-up time, impractical. Because the robot is so easy to teach, the right cleaning and lubrication pattern for a particular die is readily achieved.
- Loading inserts and unloading the casting. Inserts of materials different from the casting alloy can be joined to die castings during casting. For example, a steel shaft needed for strength and hardness can be set into a die-cast gear wheel, or a sleeve of bearing material inserted where bearing demands are too severe for the casting alloy.
Spot welding
Welding joins metals by fusing them together. This differs from soldering or brazing, where joints are made by adhesion using an alloy with a lower melting point, such as lead, tin or silver.
For hundreds of years blacksmiths have welded wrought iron by heating the pieces almost to melting point and hammering them together on an anvil until they become virtually one piece. In modern welding, the heat comes from gas torches, electric arcs, or an electric current passed through the metals where they're to be joined.
In spot welding, metal pieces are joined at a number of small, localised spots by passing a large current at low voltage through the metal at each point. Sheets rather than large structures suit spot welding, since more massive pieces conduct heat away too quickly to reach fusion temperature.
The heat in spot welding comes from the work done by the current in overcoming the small but finite resistance of the metals, so the process is also called resistance welding. For a given current, the higher the resistance, the more heat is generated. In practice the materials are clamped between copper or copper-alloy electrodes that carry the current to the weld. As current flows from one electrode to the other, heat builds up in the column of material directly beneath the electrode tips, and if it's enough to fuse the materials, a weld forms at that spot.
The welding sequence (squeeze, weld, hold, off) is so short that most of the time on a multi-weld job goes into moving the gun between spots. Because the gun is unwieldy to handle for long periods, and the operator must judge where to place each weld, manual spot welding isn't very precise. This raises the question of automating it, both to remove drudgery and to improve accuracy. Where the product is unlikely to change much over a long period, such as a refrigerator cabinet, special-purpose automation would be justified. But where the line changes often, that's uneconomic. This is the situation in the motor industry, where models traditionally change every year and three or four body styles may be built on the same line at once. Here the robot welder comes into its own.
Over the past decade, automotive spot welding has been the main application of industrial robots worldwide. It's by no means simple; it's very complex. Yet in many ways a robot's characteristics suit it ideally. The robot's entry came through painstaking development by robot makers and cooperation from the car makers, the most profit-conscious industry of all. About 15 years ago, body parts, some of them large sub-assemblies, were held in clamping jigs and tacked together by workers using multiple welding guns, then finally spot welded by operators placing welds by eye. In 1966 the first steps were taken to have a robot guide the welding tongs, linking its controller to external signals that told it when to squeeze, weld, hold and so on. By 1969 General Motors had installed a line of 26 Unimates to spot weld car bodies, followed in 1970 by Daimler-Benz in Europe, which adopted a Unimate for body-side spot welding.
From those beginnings the use of robots here has mushroomed, and the process is so important that car makers now have to consider robots' capabilities and limitations when designing the production line itself. Step by step, robots have been introduced into body spot welding until more than 1,200 are now in use.
To take its place on a car production line, a robot must be able to remember several body styles. That's difficult, because cars are designed for looks, so their geometry gives the robot little help in establishing reference points compared with more functional shapes like appliance housings. Having absorbed this information, the robot must on command start the right program for the body coming down the line, then perform a series of complicated manipulations with a heavy welding gun, with speed, accuracy and reliability, in an industry building up to 80 bodies an hour.
This is a job for high-technology robots like those from ASEA, Cincinnati, Kuka, Comau, Kawasaki and Unimation, all of which are found in this application today. They often work three shifts, though the third is usually shortened to allow maintenance of the whole line, not just the robots. Their repeatability and positional accuracy give much more consistent results than human operators. In fact, body strength can be achieved with fewer welds, correctly placed, than a human operator could reliably produce.
Much robot work is respotting: a body that has been tacked together is finally welded by a group of robots on the line. The group is controlled by a single supervising computer that signals the arrival of a particular body style and switches the robots to the right program. Interlocks and sensors can easily be added so the robots know what they're making and when to start and stop. Robots thrive on the kind of commands inherent in spot-welding cycles.
All major car makers now use robots on their production lines. Some, such as Volkswagen, Renault and Fiat, have developed and built their own robots specifically for spot welding.
In Gothenburg, Sweden, Volvo runs the largest and most sophisticated automatic welding line in the world. A line that once needed a workforce of 67 has been replaced, at a cost of US$6 million, by a robotised line served by a handful of key staff. It's scheduled to produce 50 bodies an hour in a mix of two-door and four-door models, aiming to improve the working environment and produce a more consistent product. It was designed by an Italian company that had already installed robot welders at Fiat in Italy, Fiat being Europe's biggest user of robots among car makers.
The line has several novel features and is the most advanced yet built. It has ten workstations linked by a conveyor, with bodies at every stage mounted on pallets. It runs on two levels: welding on the upper, and pallet return on the lower. The welding line is indexed while the return line moves continuously at about 50 feet per minute, letting pallets gather near the start so they're available when needed. What matters most here is the role of the robots, best described station by station.
- Loading. Body sections are loaded onto a pallet. No robots.
- Tacking. Body parts are held in position by swinging gates while six horizontal robots (Unimate 4000B) and one vertical (Unimate 2100) tack them together with 128 spot welds.
- First respot. Three robots, two horizontal (4000B) and one vertical (2100C), make 82 spot welds.
- Second respot. Five robots, four 4000B and one 2100C, make 138 spot welds.
- Roof fitting. Conventional automation and robots work together: the controller selects one of two roofs, normal or hatch, and places it on the shell precisely enough for a Unimate 2100C to fix it with 14 spot welds.
- Roof finishing and check. A robot finalises the roof by welding in the drip channel, while an operator loads tie-plates into an automatic transfer machine that positions them for welding. Six robots (four 4000B and two 2000C) make 176 welds.
- Seam welding. No robots: four template-guided welding guns each make 60 overlapping spot welds to form a seam, moving at about 7 feet per minute.
- Final respot. Five robots (four 4000B and one 2100C) make 156 welds to complete the body.
- Back-up and checking. If a robot develops trouble, people can complete the body here.
- Unloading. The body is unloaded and the pallet returns along the lower level.
This is typical of robot spot welding, yet the application is relatively simple. Only two body styles are involved, so the robots are nowhere near the limits of their memory.
Arc welding
Spot welding doesn't suit every weld, especially long joints that need a gas-tight seal. For those there's arc welding, in which the heat to fuse the surfaces comes from an electric arc: a sustained spark or discharge between two terminals, here the work and a metal electrode.
When the arc is struck, the local temperature rises rapidly to as much as 6,500 °F. A small pool of molten metal forms in the work, and the tip of the electrode melts too, adding metal to the pool. The electrode must conduct electricity and be compatible with the metal being welded. A typical electrode is a metal wire fed continuously at the rate it's consumed.
Arc welding creates an unpleasant working environment. The intense glare of the arc carries considerable ultraviolet radiation, so the operator must wear nearly opaque goggles or a mask to protect the eyes. Sparks fly around the shop and smoke is generated. It's little surprise that it's hard to find welders willing to work a full shift in these conditions while producing consistent, repeatable results. Once again, enter the robot, unaffected by the environment and virtually incapable of deviating from a well-defined task it has been taught.
Most arc-welding jobs need a robot with about five articulations, because the welding gun is a symmetrical tool. An attractive feature of robot arc welding is that it's true human replacement: it uses perfectly standard welding equipment and needs little specialised kit. All that's required is a mount to fix the gun, with its gas lines and wire feed, to the robot's hand. Everything else works as normal.
The robot's job is mainly to guide the gun around the programmed path and signal when it's in position and ready. The welding controller does the rest.
Spray painting
Spray painting is commonplace even at home, with aerosols or simple workshop compressors and spray guns. But it's the car industry that has set the standard for high-quality, even finishes, and car makers have done much research into paints that flow easily, minimise runs and dry before dust can settle.
It's worth looking at how a human sprayer works. Holding a gun pressurised by air and fed with paint from a small tank or a central reservoir, the painter squeezes the trigger to release a fine spray carried in the airstream. The paint's viscosity must be just right to atomise finely and not spit lumps that spoil the finish. The spraying distance is also critical, to give a coat thick enough to cover but not so heavy that it runs. The operator controls the process by keeping the gun moving, applying thin rather than thick coats, and going back over thinly coated areas to build an even layer with a good finish.
The spray shop has always had a reputation as one of the worst environments people have to work in. Keeping it dust-free at the right temperature means making it as small as possible. Some early spray shops were real death traps, though legislation now sets codes for operators' health and safety.
The solvents are toxic and pollute the air, so ventilation must give the operator an abundant supply of fresh, clean air. The ideal layout for this may be far from the best arrangement for line painting, so compromises are needed. Painters have worn masks since the technique began.
More recently, attention has turned to noise. The noise in a busy spray shop, from air discharging through fine nozzles, can cause irreversible hearing damage over an eight-hour shift, so current standards require ear plugs. There's also the fire hazard from highly flammable materials.
Finally, as if that weren't enough, some pigments are suspected carcinogens. This, together with proposed regulations on hydrocarbon emissions from factories, will probably bring major changes in practice, such as water-based and urethane paints. The whole field is ripe for further research and development.
The hostility of the spray shop has always made it a prime candidate for taking the human operator out of the process, avoiding many of the costly protective measures now being demanded.
Car production, with its competitive approach, has been fertile ground, and many spray-painting machines have been introduced. Generally, though, they're limited and almost always need human operators to touch up areas they miss. They also tend to waste more paint: typically they paint in horizontal and vertical passes on a reciprocating system. Banks of guns fed from large central reservoirs move to a predetermined program and manage to cover some 70–80% of the exterior. Less accessible areas such as wheel arches, the inside of the body and the engine bay must be painted by operators who look for missed areas as bodies leave the machine. Colour changes have to be scheduled, since they mean changing or switching reservoirs and clearing the old colour from lines and guns to avoid contamination.
The method is well established but recognised as far from perfect. Its energy demands are enormous: it takes about 25 million BTU to build a car, much of it to supply fresh air to the spray booths. Since governments will demand cuts, car makers have a strong incentive to get people out of the paint shop wherever possible, quite apart from the economic advantages.
There's little doubt that the robot offers the car builder the best chance of success, faced with constant design changes, new colour and finish fashions, and buyers who want high quality at low cost in a product that must look good as well as perform.
One car maker's justification for robot painting gives an idea of what they expect from their massive investment:
- Robots will let us deal with a hostile environment: noise, carcinogenic materials and particulate matter.
- Robots will let us process with less energy: less fresh air, less exhaust and lower energy costs.
- Robots will improve paint quality: less dirt, uniform build, a consistent quality level, and the ability to handle specialised spray techniques.
- Quality improvements will reduce warranty claims and in-house repairs.
- Material costs will fall.
- Direct labour costs will fall.
To meet what will clearly be a lucrative market, several robot builders are preparing robots for this application, and competition may be fierce in the years ahead.
Robot economics
The success of any commercial undertaking has to be measured financially. The most brilliant technical innovation is a failure if it loses the entrepreneur or shareholders money. Robots are no exception. Whatever the social benefits, however clever the technology, however pretty the robot is to watch, every proposed robotics investment must pass a critical financial appraisal.
The following headings give a framework for analysing the costs and benefits of a robot installation.
Purchase price. Highly variable, especially if simple pick-and-place devices with few articulations are counted as robots. The range might run from £5,000 to £100,000, depending on the number of articulations, working area, payload and control sophistication. Generally, higher-priced robots can do more demanding jobs, and their control sophistication means they can be adapted to new work when the original job ends. The more expensive, sophisticated robot will also normally need less special tooling and cost less to install. Some pick-and-place robots are no more than adjustable components of automation systems; one popular model rarely accounts for more than 20% of total system cost.
Special tooling. This can be as little as a £300 gripper for a robot at a die-casting machine. Or it may include an indexing conveyor, weld guns, transformers, clamps and a supervisory computer for a group of robots spot welding car bodies. For assembly automation, the special parts may cost well over the cost of the robots.
Installation. Sometimes charged fully to the robot project, but often carried as overhead because layout changes were happening anyway. A model change usually brings installation costs even if equipment is to be manually operated. There's no logic in charging the robot installation more than the extra cost that robotising actually brings.
Maintenance and overhaul. Keeping a robot working properly needs regular maintenance, periodic major overhaul, and occasional repair of unscheduled breakdowns. A rule of thumb for well-designed production equipment run on two shifts is a total annual cost of 10% of the purchase price. This has been borne out by thousands of Unimates, many of which have had several overhauls while clocking up as much as 10,000 hours each. It varies with the demands of the job and environment: maintenance in a foundry costs more than in plastic moulding.
Operating power. Easily calculated as average power draw multiplied by hours worked. Even with rising energy costs, this isn't a major robot cost.
Finance. Some justification formulae take the current cost of money into account; others use an expected return on investment to establish viability.
Depreciation. Robots, like any equipment, have a useful life over which the investment is normally depreciated. Since a robot tends to be general-purpose equipment, there's ample evidence that an 8- to 10-year life on multi-shift work is a conservative assumption.
On the benefits side:
Labour displaced. The prime issue in justifying a robot. Industrialists are mildly interested in shielding workers from hazardous conditions, but the key motivation is saving labour cost by replacing a worker with a robot. It's all the better if one robot can work more than one shift, multiplying the saving.
Quality improvement. If a job is hazardous, physically demanding or simply mind-numbing, product quality will probably vary with a human worker's mood. A robot may be more consistent and so produce higher-quality output.
Increased throughput. Higher quality naturally means more net output when a robot just matches a human worker's pace. But often a robot can work faster and increase gross output too. Greater throughput is valuable in itself, and better use of capital assets may add considerably to the benefit of one-for-one worker replacement.
Project appraisal by the payback method
Payback calculation is the simplest form of project appraisal. It rests on two questions: how much will it cost, and how soon will we recover the investment?
Here's a simple example. A robot is being considered for a workstation operating 250 days a year, where it would replace one worker whose wages and benefits come to £12 an hour. Against that saving, the robot would cost £1.30 an hour to run and maintain. The capital investment for the robot and accessories is £55,000. The company normally works one eight-hour shift a day, but can move to two shifts when demand is high enough.
The simple payback formula is:

where P is the payback period in years, I the total capital invested in the robot and accessories, L the annual labour cost replaced by the robot, and E the annual cost of running and maintaining the robot.
In this example I = £55,000, L is £12.00 an hour and E is £1.30 an hour, over 250 working days a year of one or two eight-hour shifts.
Case 1: single-shift operation
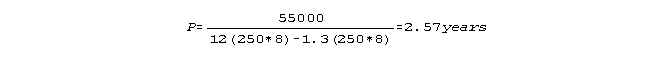
Case 2: two-shift operation
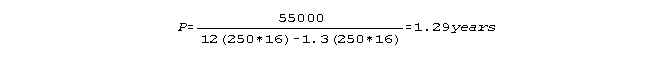
With one eight-hour shift on each of 250 working days, the payback period is about 2.6 years, which would probably satisfy the company's accountants. If sales forecasts and production plans show two-shift working can be sustained, the payback period falls to around 1.3 years, which surely justifies going ahead without any doubt at all. Or does it?
At first glance there seems no reason to hesitate. But two points can dampen the optimism of these payback figures.
The first concerns robot upkeep costs. The figures above apply to a company that already has some robots and so has the capability and organisation to maintain and reprogram them. If this robot is a lone newcomer, the first of a population of one, the company must set up a maintenance facility from scratch, and all its costs will fall on that single robot, adding both to the investment and to annual upkeep. If it's the second robot, things look much rosier: the maintenance facility already exists, so there's virtually no extra investment, and total upkeep for both is far less than double that of the first. For practical and economic purposes, robots are a far better proposition once the robot workforce numbers more than three or four.
The second objection only becomes apparent when spending or returns are considered over two, three or more years. For very short payback periods there's no hidden snag and no correction needed. But when payback periods are long, or return on investment assumes writing the investment off over several years, discount factors must be applied. Discounting recognises that a pound spent today costs more than a pound spent next year, since delaying the spending lets the money earn interest. Conversely, money earned next year is worth less than the same sum earned this year. These effects grow with the number of years involved.
Sociological impact of robots
Quality of working life
No one will dispute that robots offer unique advantages to workers who would otherwise spend their whole day amid noise, vibration, smells, smoke, extreme heat or cold, oil spray, flying chips, monotony or risk of serious injury. If, for example, a robot replaces a worker in a die-casting shop, that worker can move to another job in the plant where they no longer breathe die-lubricant fumes, no longer have hot molten zinc spurting at them, no longer wear asbestos gloves as standard, and can work as a person rather than an eight-hour-a-day zombie.
Social improvements usually run up against a lack of funds. Robotics is often the exception: moving workers into better jobs goes hand in hand with higher productivity at the robotised station. Die casting and press operation are just two of many examples where moving machine parts pose real danger to those tending them. There must be many other jobs, not only in manufacturing, where people are at risk and robots could take over. It could be argued that those who make and sell industrial robots have a moral duty to prioritise the areas of industry where people are degraded by their work or put in actual physical danger.
Attitudes to robots
People are generally suspicious of change. Whether it's a new road, a new airport or automated plant in a factory, someone somewhere will object. Even a new employee is regarded sceptically until they've proved they fit in. Much opposition comes from fear, and fear is born of ignorance. Every worker wants to be assured that change won't worsen their conditions, cut their earnings or make their job redundant. If management fails to tell its workers about coming changes, keeps them unaware of the reasons, and doesn't discuss the effect on individual livelihoods, people naturally become afraid, resentful, worried and hostile.
Robots are perhaps a special case. They bear some resemblance to people, because they act autonomously and simulate some human actions, and fiction has long taught us to treat them warily. When a robot is introduced into a factory, there would seem to be every reason for a mass walk-out.
Yet since robots were introduced in the early 1970s, case histories show qualities that never occurred to market analysts. The still relatively small robot population has already interacted with human co-workers and union leaderships. Initial curiosity gave way to tolerance, and finally to something very like rapport in many factories.
As evidence mounts of this remarkably benign reaction, it's interesting to speculate why. An industrial robot is pathetically sub-human: deaf, dumb and, until very recently, blind. The emotion it most clearly arouses in its human colleagues is amused affection. Notably, a General Electric study of robot implementation found that management conservatism or hesitancy was a more serious obstacle than rejection by workers.
Effect on employment
While quality improvement and increased throughput produce some savings, labour displacement is the central benefit: robots contribute to productivity mainly by displacing human workers. The benefits are clear, but what about the social costs?
Even if no individual can point to a particular robot and say it took their job, it's surely true that robots have eliminated jobs. So far the impact is minuscule. By the end of 1985 there were some 15,000 robots installed worldwide; considering that many work more than one shift, displacement might total 20,000. The net employment effect of creating a robotics industry may even be positive, counting those who develop and build robots and those who supply the industry. This perhaps suggests that unskilled or semi-skilled workers are being taken out of companies and replaced by new staff to tend, maintain and program the robots.
Robotics is so new that there's no history from which to predict the social cost of job displacement. But technology in general, and automation over the past century in particular, can be evaluated on a cost–benefit basis.
Consider productivity gains in US farming. In 1870, 47% of the US population worked in food production; by 1970, just 4% produced all the nation's food plus a vast surplus. There was dislocation over those 100 years as people left farms for cities, but the benefits have greatly outweighed the costs.
What can reasonably be expected of robotics for the rest of this century? Many independent surveys arrive at an average annual growth rate of about 35%. At that rate the robot population would be growing by some 40,000 a year by 1991. Current technology won't support such growth, but robots with rudimentary vision are already appearing.
Forty thousand robots entering the workforce each year is certainly a large number, but not a disruptive one. It represents about 0.06% of the blue-collar workforce in the industrialised countries where they'd be used. There will of course be other automation influences on productivity besides robots, which will probably eclipse robotics, since automation is already so much a part of manufacturing. And automation aimed squarely at specific segments of manufacturing is more likely than robotics to disrupt employment.
Robots will enter the workforce gently, without concentrating on any one job activity. Productivity achieved without massive displacement is the most socially acceptable. All productivity gains are good, but an influence spread widely enough to have no more impact than natural turnover is the most readily absorbed.
Labour leaders will ordinarily support productivity improvements as long as they don't come from some disguised speed-up or cause massive displacement, and as long as union members share in the economic benefit.
In short, robotics will contribute importantly to humanity's material well-being without painful dislocation of individual workers. If, 50 years from now, the working week is three days, the air and water are clean again and industrial life is ever so desirable, we shall be at least partly beholden to robotics.
Future capabilities
The following robot qualities sought for the future are listed in order: number one, rudimentary vision, is the most likely to have a profound effect in broadening the applications of robotics.
- Rudimentary vision. Vision lets a robot recognise things and work out where they are. Vision systems are already available that are good at locating an individual dark part on a white background, letting the robot pick out parts that may be disorientated. With such basic sight, the robot can be helped by keeping some order in how parts are transported through the factory: palletised parts are much easier to find than parts dumped randomly in a box. Research continues feverishly, and with cameras getting cheaper and sharper and computers faster and more powerful, robots with good vision are bound to arrive.
- Tactile sensing. A robot with a sense of touch could recognise parts the way we do in a darkened room, just by feeling and groping. More important is a sense of what's happening as parts or tools interact in its grippers. We all know the experience of putting a nut on a bolt in a blind location: we instinctively back-thread until we feel a click, then run the nut forward slowly to avoid cross-threading. That kind of tactile sense would greatly enhance a robot's capabilities.
- Hand-to-hand coordination. For a robot with more than one arm to pass a part or tool between its grippers takes more computing power and better software.
- Mobility. For most factory jobs the robot need only stand in one place. But some jobs call for a roving operator tending widely separated stations that need only occasional attention. So far this has been done by mounting robots on rails between workstations. What's needed is a robot that can literally stroll.
- Minimal space. Most robots need substantially more floor space than people. The cost of re-laying equipment and providing floor space can wipe out the economic case for a robot. A robot as compact as a person, needing less space than today's, is required.
- Energy-saving power systems. Robots use far more power than people ever will. Energy use isn't yet a pressing issue in robotics, but it may become one, so research into more efficient robot "muscles" is needed.
- General-purpose hands. Sometimes one type of gripper isn't enough. A gripper as universal as the human hand, usable for many applications, needs to be developed.
- Voice communication. With advances in computers and software, it's now possible to build a robot that can speak. With speech recognition it could be reprogrammed by spoken commands, or use synthesised speech to explain its view of the work or report internal faults.
- Self-diagnosis. As robot design advances, hardware complexity will increase. A robot computer that can analyse itself and indicate the fault area would cut repair downtime and keep production going.
Conclusion and inference
The major benefit of robots, especially in manufacturing, will be to improve working conditions by taking over dirty, heavy and repetitive jobs. This is bound to improve the lives of those who would otherwise be committed to such tedious work. On the other hand, there must be concern about the loss of jobs they take over. In vehicle manufacturing especially, even if output rises significantly, no new jobs will be created in those departments. This will greatly concern the unions, because the robot explosion began in a recession, and as robotics grows, the workforce will shrink and union power with it.
As a counter to this, more skilled workers will be needed. The growth of robots in industry will lead people to spend less time at work. Perhaps the whole idea of work needs rethinking: perhaps employers should send employees at every level on education courses to gain the skills modern industry needs. People will need to be motivated to work more conscientiously than ever, yet may eventually work far fewer hours each week, and will need to be more imaginative in how they think at work.
In fact, the effect of robots on overall employment is certainly exaggerated. In a national manufacturing industry employing, say, 10 million people, an increase in the robot population from 300 to 5,000 will have a negligible effect on employment, as long as management and employees are committed to staying competitive. The recent recession showed that companies that let themselves become uncompetitive suffer much more, and much faster, than they used to. If each manufacturing company can grow by just 1% a year, an extra 10,000 people per million employees will be needed. So in an industry of 10 million people, 100,000 people, or about 50,000 robots, are needed to raise output by 1%.
Clearly, a country the size of Britain is unlikely to install 200,000 robots in the next few years; 1,000 a year is more likely. So in the short term at least, the effect on overall employment will be negligible. If a good proportion of those robots are made where they're used, the effect will be smaller still. But where unemployment does appear will present government and people with major problems, especially where there's no real commitment to staying competitive.
It's also clear that the nature of employment will change. Whether office workers will actually work at home in large numbers, as some forecast, is by no means certain. We can say that people will do less with their hands than now.
Forging and machining will be automatic, robots will do almost all handling and assembly, and special tools with some robotic features will spread into the service industries. People will spend more time watching or checking operations rather than doing them. This will be just as true of engineers and designers working with CAD/CAM systems.
While jobs will certainly be lost to robots, there are also great opportunities for engineering companies to produce them. There are bound to be thousands of openings for designers, engineers, systems engineers and software writers to compete in producing robots for the market. Perhaps one of Britain's major managerial faults is its lack of interest in new technology. If companies don't research robot design, Britain will, as usual, lose out to the Japanese and others who always seem to dominate high-tech production.
With an open European Community only a couple of years away, there's an ideal chance for Britain to start making robots and selling them into a large and prosperous market. And with huge changes afoot in the Eastern bloc, industry should be setting its sights there for customers for cost-effective manufacturing techniques.
If the robotics revolution can be used to increase economic growth, people will have the time and income to enjoy more leisure or more leisurely work. The three-day week, with four well-paid days off, has long seemed a dream. But it will only be worth having if output per machine rises dramatically. Otherwise the three-day week will arrive without the living standard to go with it.
With more time on our hands and higher incomes, there will be a temptation to buy more useless things, and a host of unthought-of products, some useful and some useless, will come from developments in microelectronics and robotics. Many manufacturers will produce more variations on short-lived products in the hope of staying profitable. So there's a real danger of squandering our resources producing more and more useless products that people buy only because they have the money. To avoid that, a sound education is the best foundation. Engineers and managers must be taught how to make the most of robots, and the technical skills of engineering workers upgraded. People must be encouraged to think more positively and expansively about work and to understand the value of the resources we have. Finally, we must educate the next generation to cope with all of this, and with the technology-intensive world to come.
Bibliography
- H. J. Warnecke and R. D. Schraft, Industrial Robots
- M. Shoham, A Textbook of Robotics 1
- J. Hartley, Robots at Work
- M. Baldwin and G. Hack, Robotics
- P. Coiffet and M. Chirouze, An Introduction to Robot Technology
- F. Horge, Machine Takeover
- Friedrichs and Schaff, Microelectronics and Society
- T. Forester, High-Tech Society
- G. Beni and S. Hackwood, Recent Advances in Robotics
- J. Engelberger, Robots in Practice
- C. Morgan, Robots: Planning and Implementation